DragonSkyTriker
Drone Simulator • Rust & Bevy 0.20
About DragonSkyTriker
no_std core • SE(3)
A high-performance cross-platform drone simulator powered by Bevy 0.20 and a rigorous physics core in no_std. Built for research, embedded firmware testing, and flight validation, it combines ultra-realistic flight dynamics, JSON-defined worlds, and a deterministic headless execution mode.
Core Capabilities
- SE(3) Physics & LiPo: Rigid-body integration (
tiny-rodriguez-nostd), 1st-order motors, linear + quadratic aerodynamic drag, ground effect, Ornstein-Uhlenbeck wind & gusts, and LiPo battery voltage/thrust sag. - SO(3) Cascaded Control: Square-root position controller, velocity loop with anti-windup integrator, drag compensation, and geometric attitude control via
log(Rᵀ R_d). - Realistic Sensors & Mahony Filter: Multi-rate noisy IMU, barometer, magnetometer, latency-compensated GNSS (10 Hz), rangefinder, and 360° × 4-channel raycast LiDAR. Fly purely on estimated state (E).
- JSON Worlds & ×1000 Headless Mode: Load custom obstacles, wind, and missions via
DST_WORLD, or run theno_stdsimulation headless at ≈ ×1000 real-time with CSV export.
Simulation Views & Modes
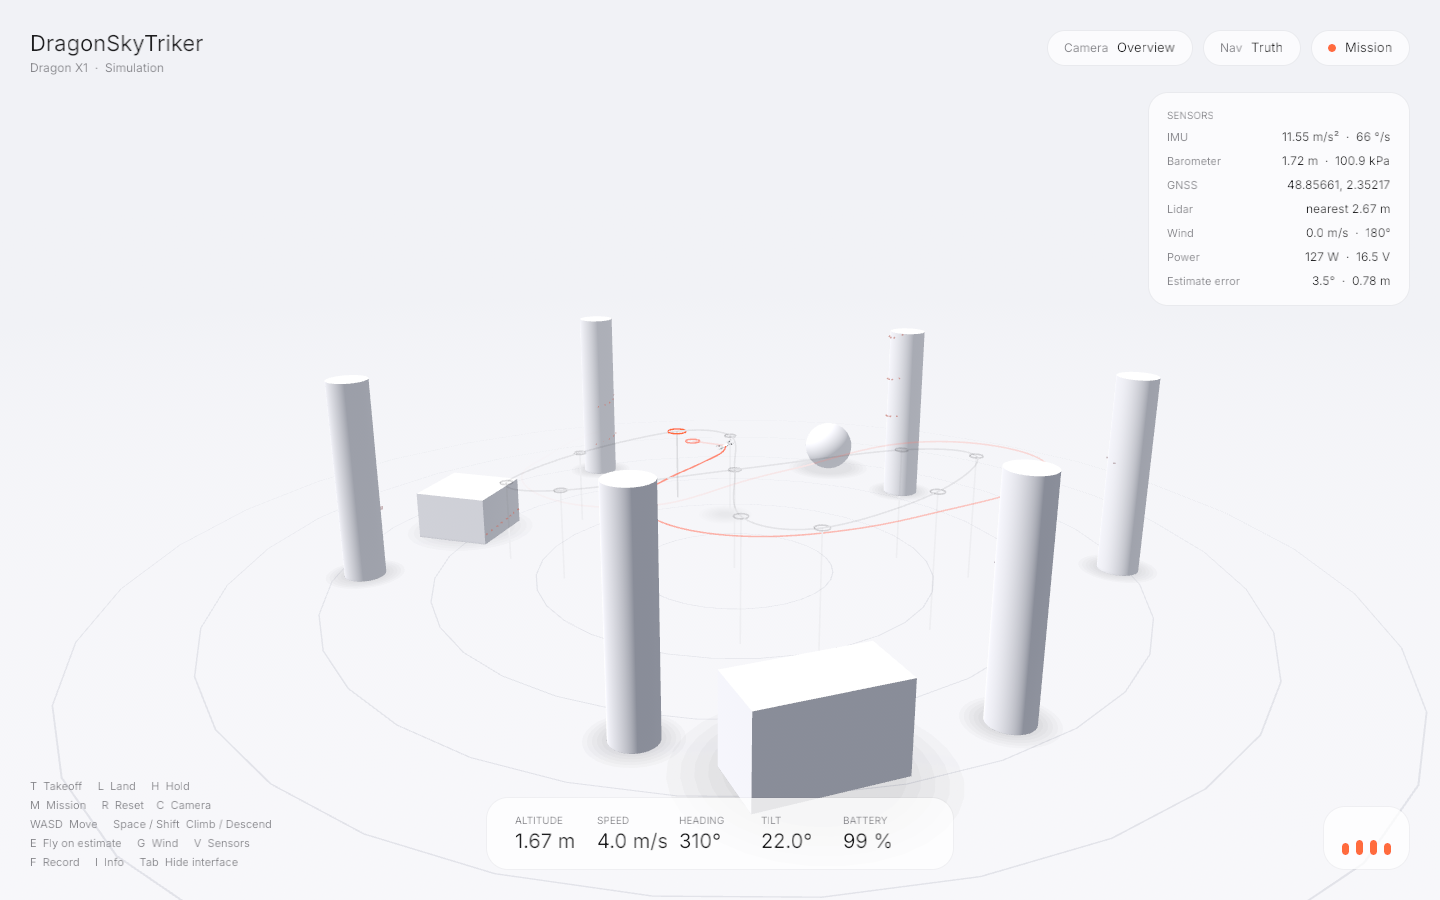
Infinite White Studio & HUD
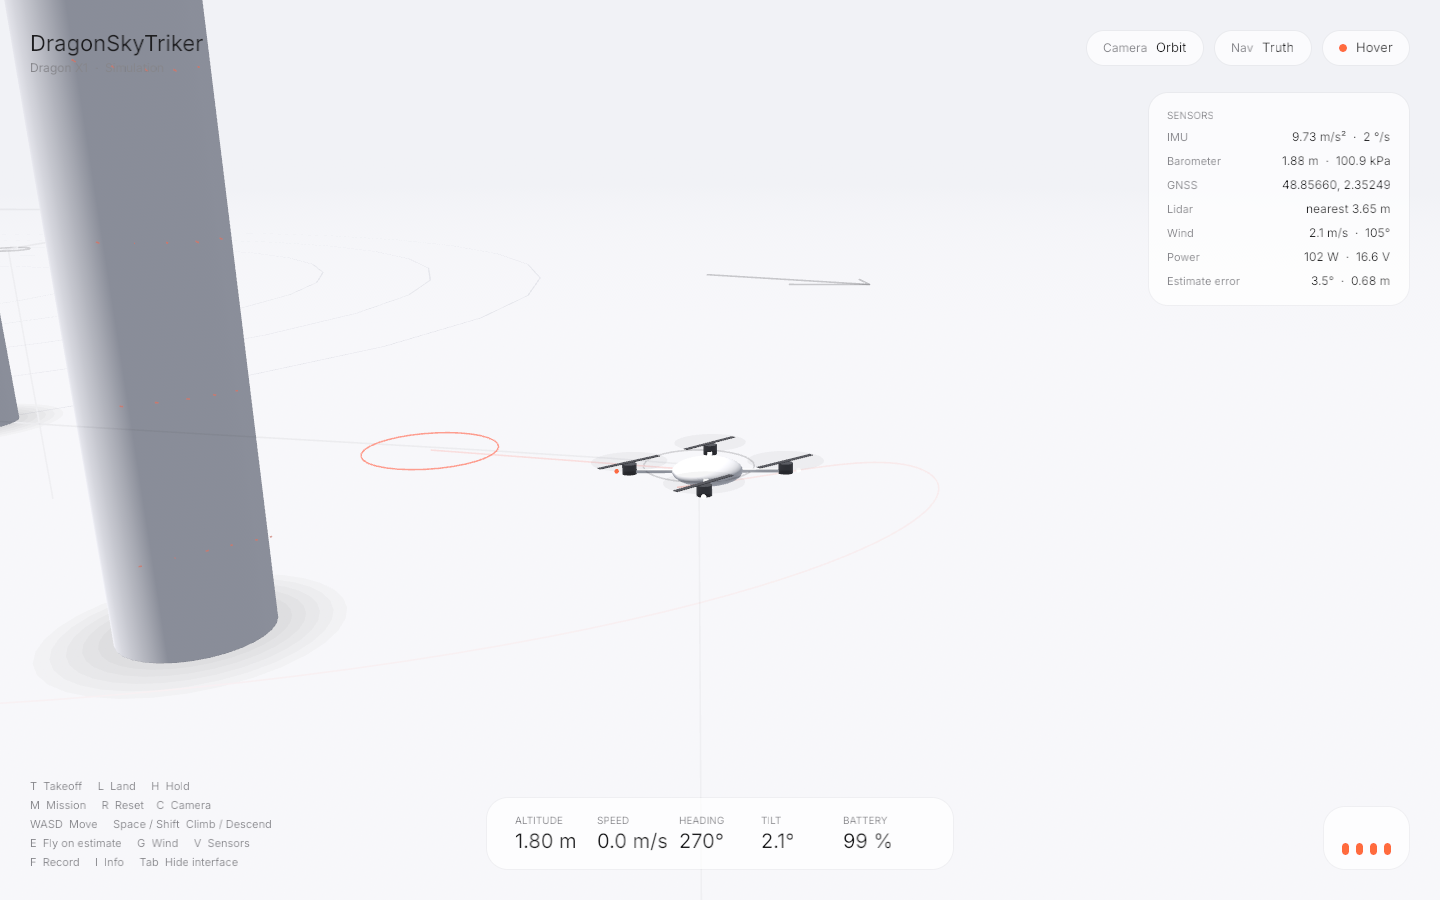
Slalom World & LiDAR Rays
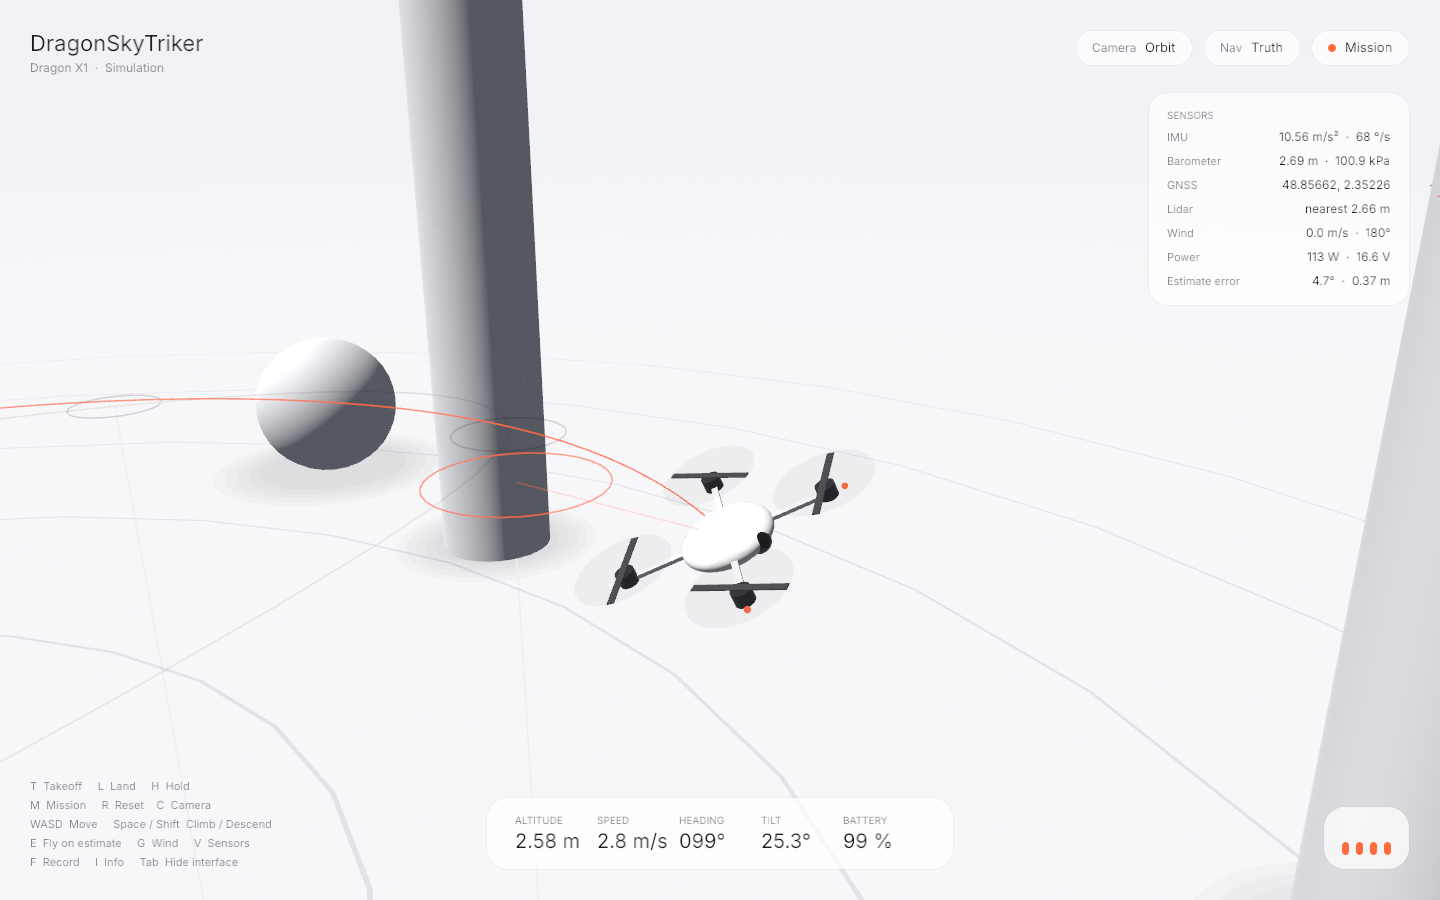
Orbit Camera & Estimation Ghost
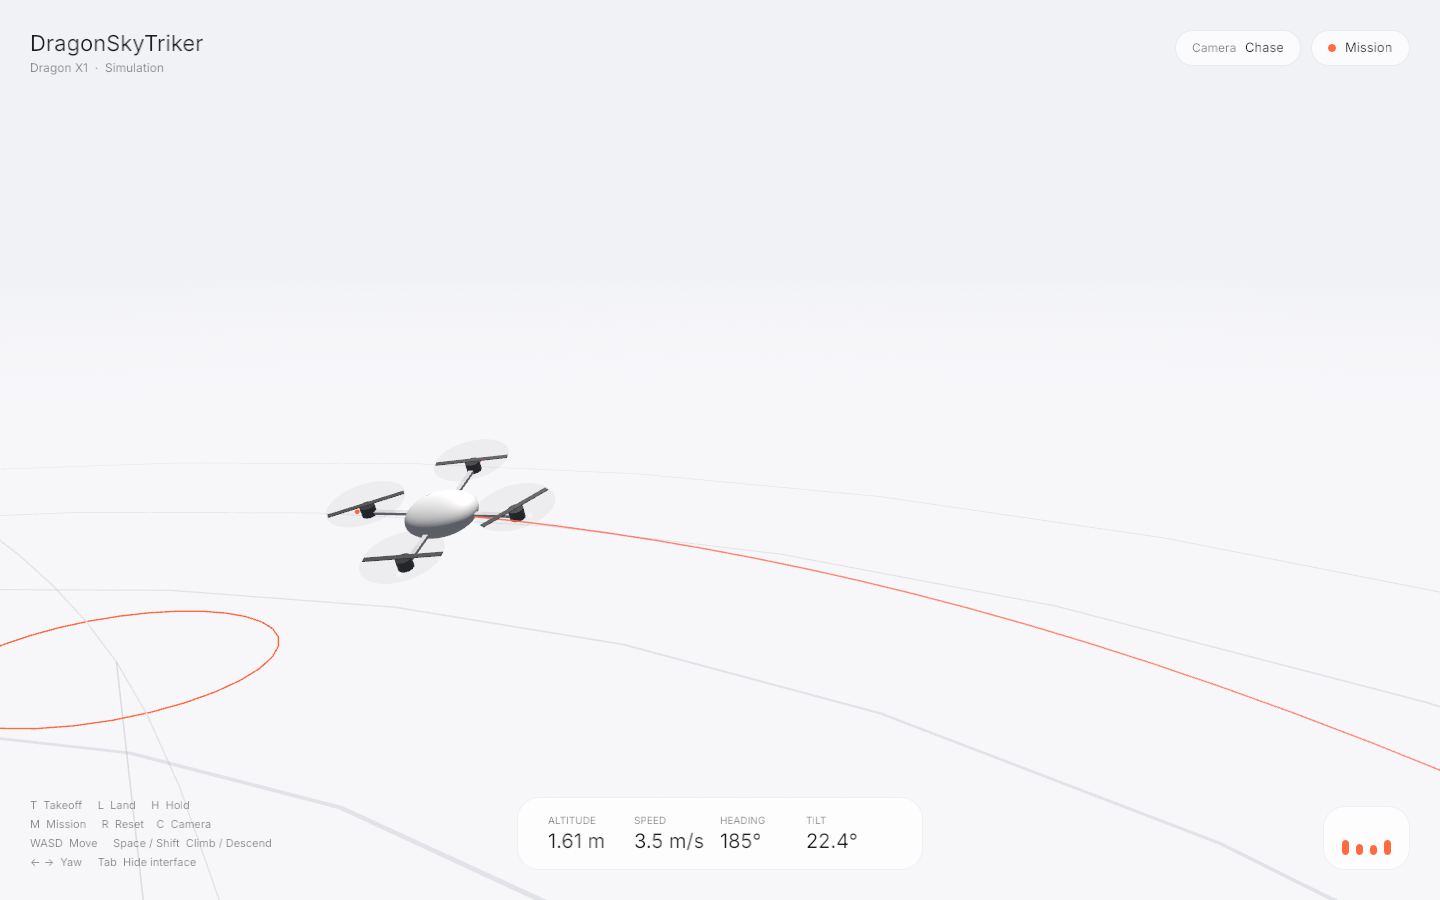
Dynamic Chase Camera
Crate Architecture & CLI
tiny-rodriguez-nostd
SO(3)/SE(3) Lie group geometry (no_std).
dragonskytriker-core
Dynamics, sensors, Mahony filter, control (no_std).
dragonskytriker
Bevy 0.20 plugin, JSON worlds, HUD, CSV logger.
DST_WORLD=assets/worlds/slalom.json cargo run --release
cargo run --release -p dragonskytriker-core --example headless -- 300 log.csv 3
Download Binaries
View source code, SDK & releases on GitHub →
GPL-2.0-or-later License • Rust ≥ 1.95
Loading comments...